The song :

Goal
The goal of the Blue Carousel Challenge (Blue for the blue boats and carousel since it should turn forever)
is to use reinforcement learning to build a controller for the blue boat
to rotate around a buoy, autonomously.
The buoy is located at the origin (0,0).
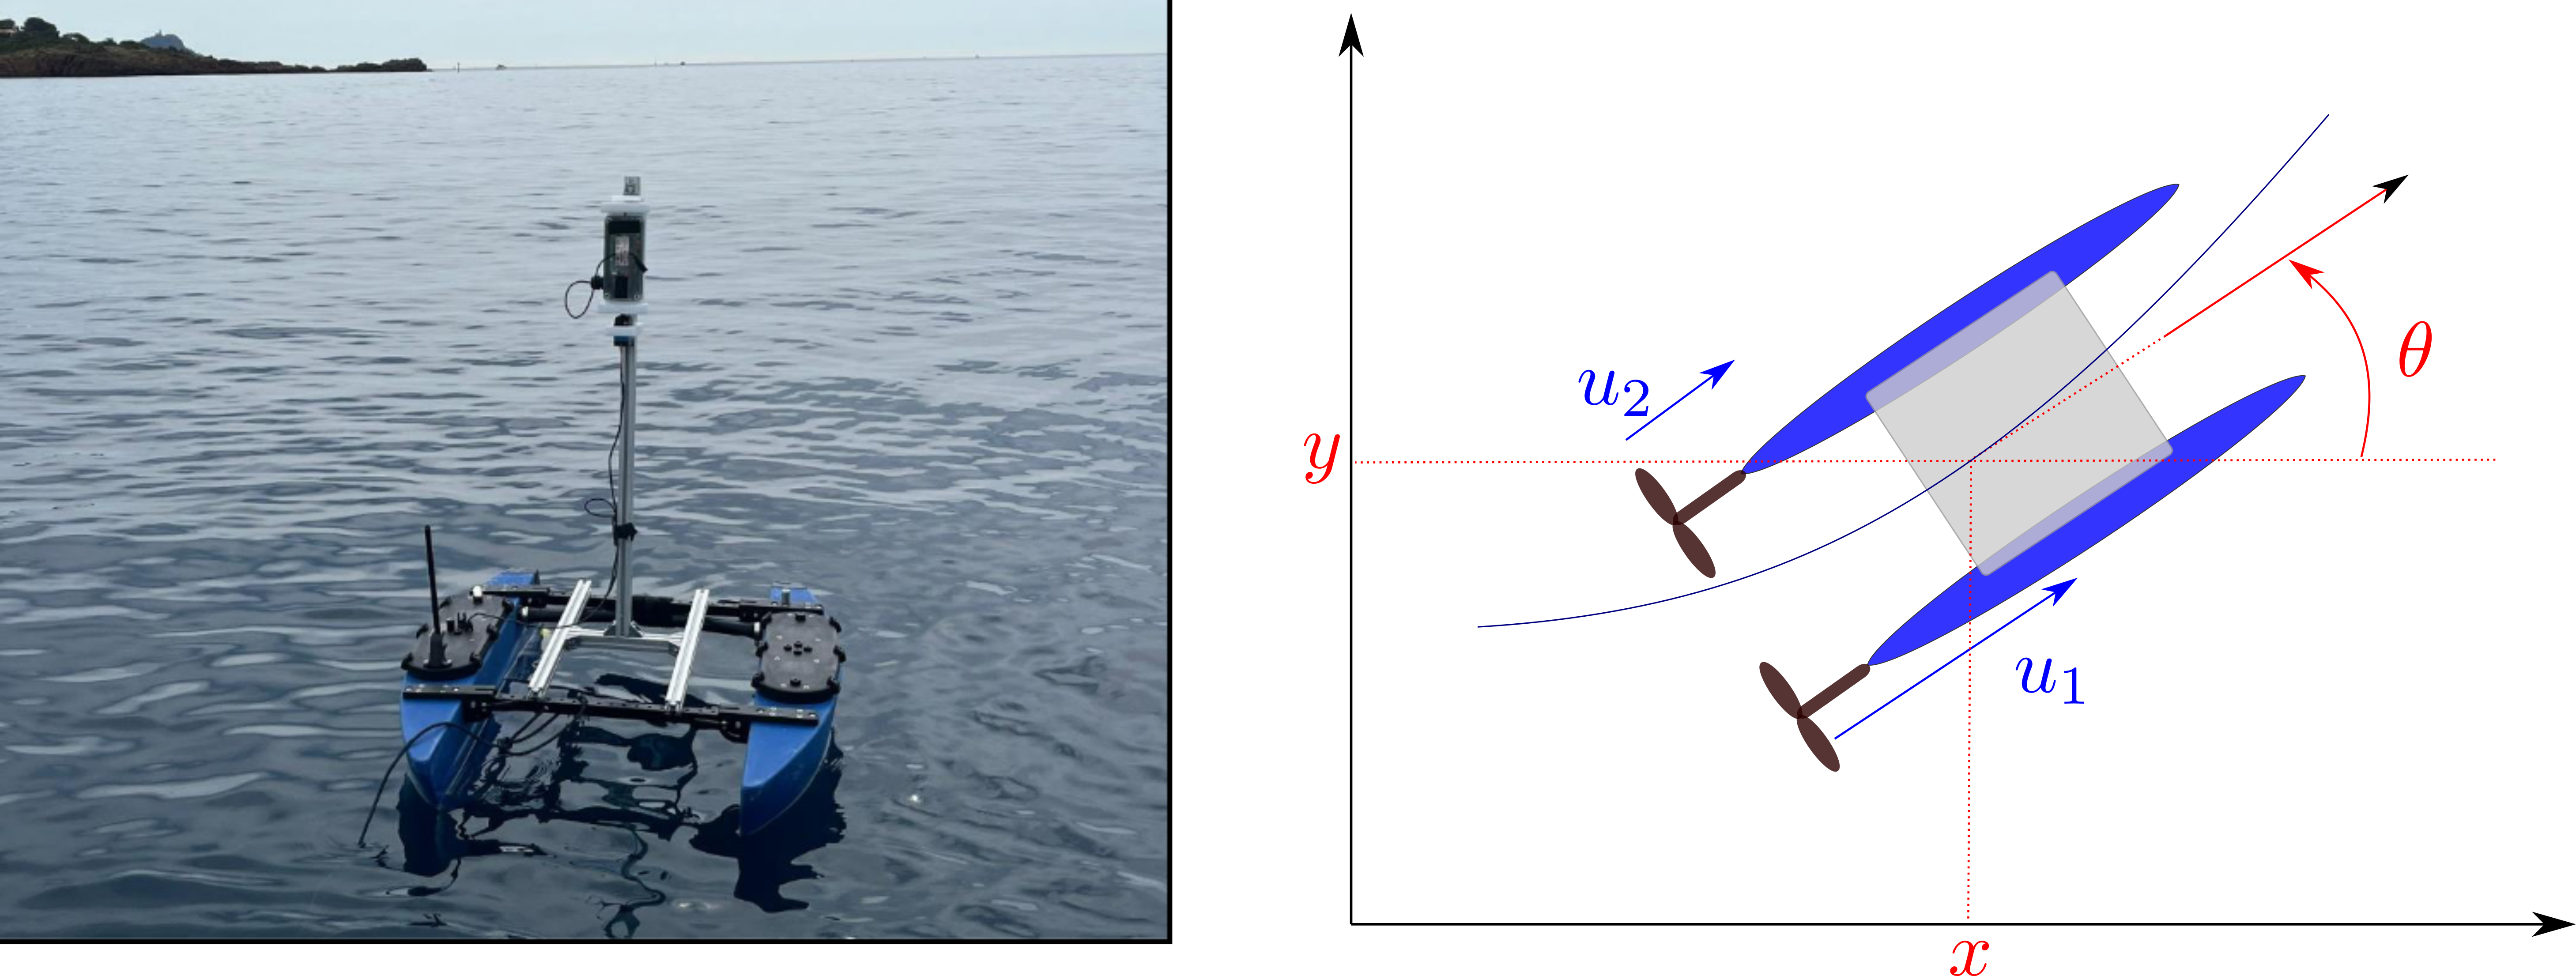
The real robot is an autonomous surface vehicles (a Blue Boat).
The robot is equipped with:
- Two propellers (u1: left and u2 right)
- State information: position (x,y) and heading θ
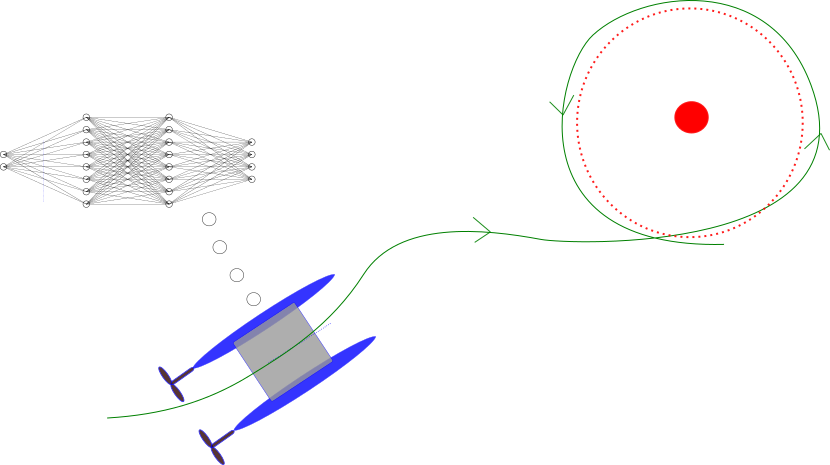
The blue boat turns around the buoy forever
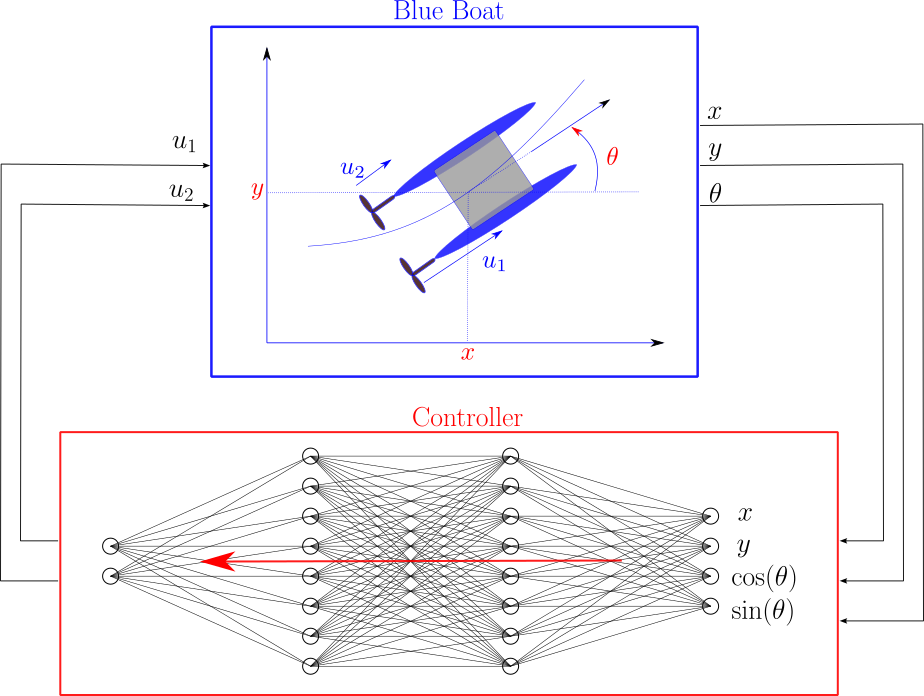
The controller receives the robot's pose as input:
x: horizontal positiony: vertical positionsin(θ): sine of the heading anglecos(θ): cosine of the heading angle
The sine and cose are used to capture the geometry of the set of angles (a disk not a line).
Controller requirements
The controller must be implemented exclusively as a neural network.
No additional logic, rules, or control algorithms are allowed.
The neural network architecture is the following:
- Input layer: 4 inputs (
x, y, sin(θ), cos(θ))
- Hidden layer 1: 8 neurons
- Hidden layer 2: 8 neurons
- Output layer: 2 outputs (
u1, u2)
The outputs correspond to the commands sent to the two propellers:
u1: left propeller commandu2: right propeller command
The neural network contains exactly 112 parameters: the weights.
Submission Format
Teams must submit their controller as a CSV file containing the 112 parameters:
- Only the parameters are allowed
- No additional code or metadata
- The robot will use these parameters directly onboard
Simulation Environment
A realistic simulator based on Unity is provided to help teams:
- Test their controller
- Train neural network parameters
- Evaluate performance before deployment
Doc (programs, ...)
Composition of the teams, programs, ... are given here :

The slides of the presentation are given here :

Galerie
Inspection de la zone par Lionel, le chef de Robex
Equipe 1
Equipe 2
Equipe 3
Equipe 4
Equipe 5
Travaux dans la salle
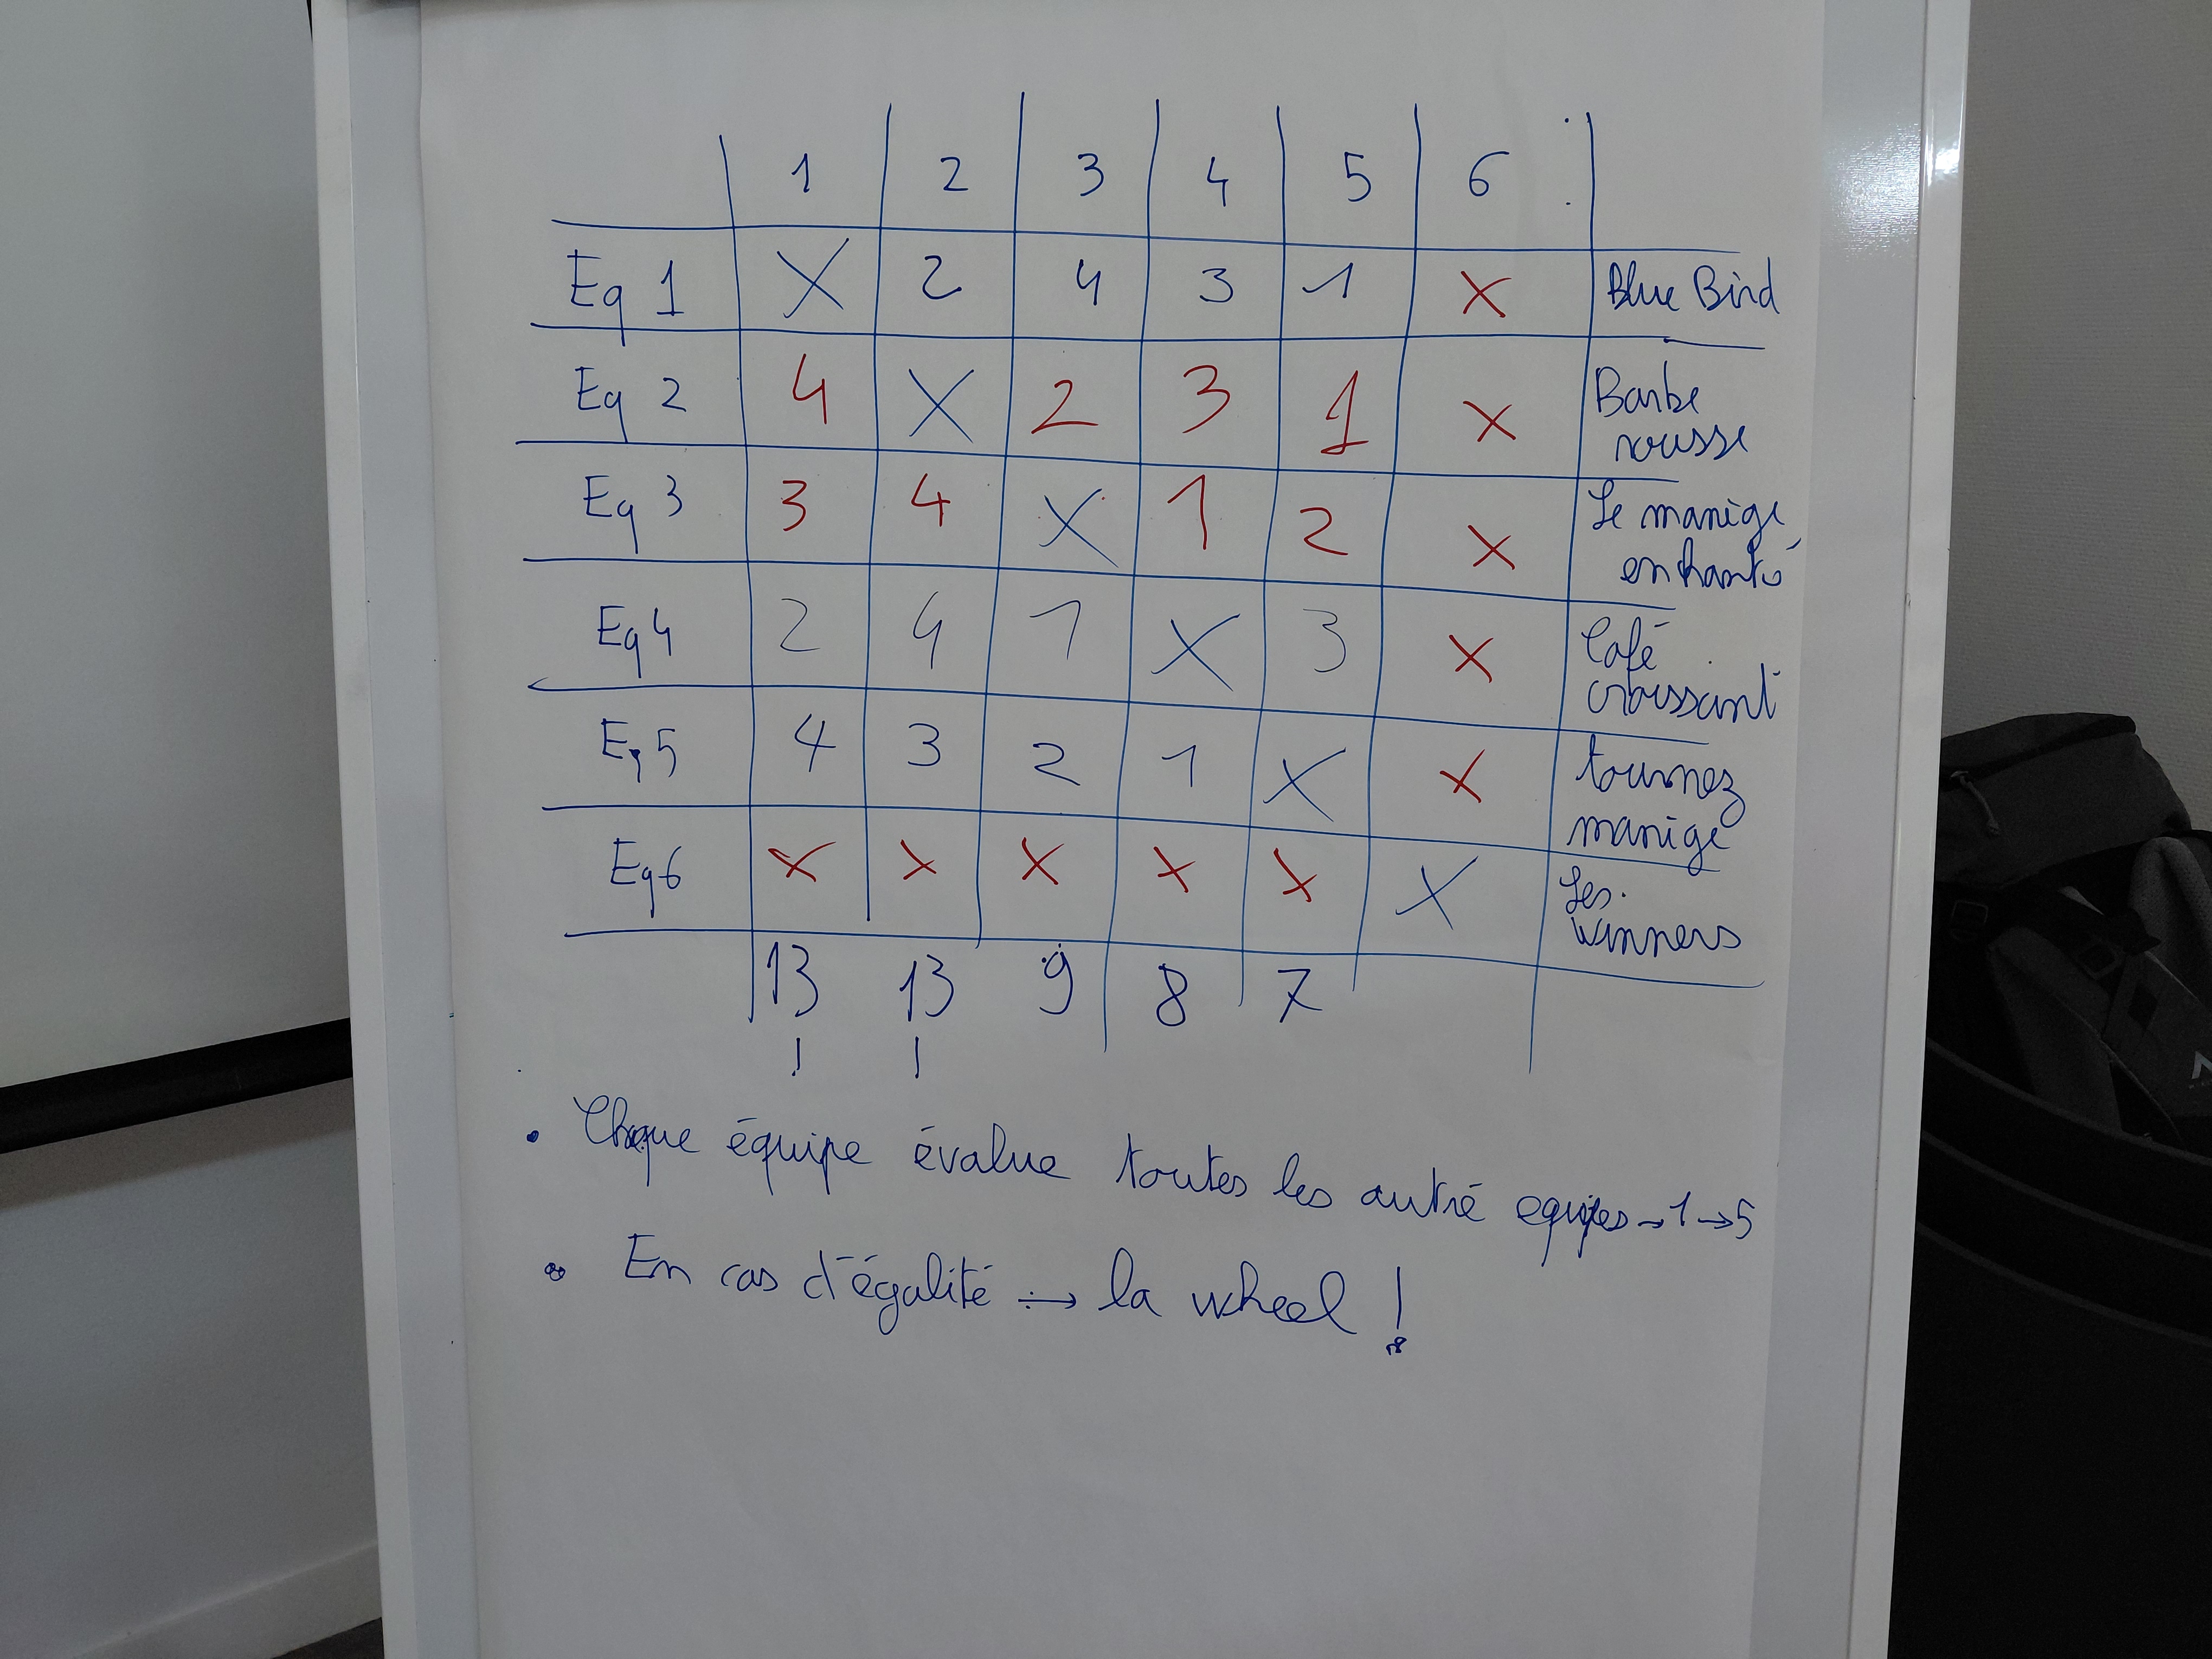
Deux équipes gagnantes que la wheel n'a pas su départager
Les deux équipes gagnantes fusionnées
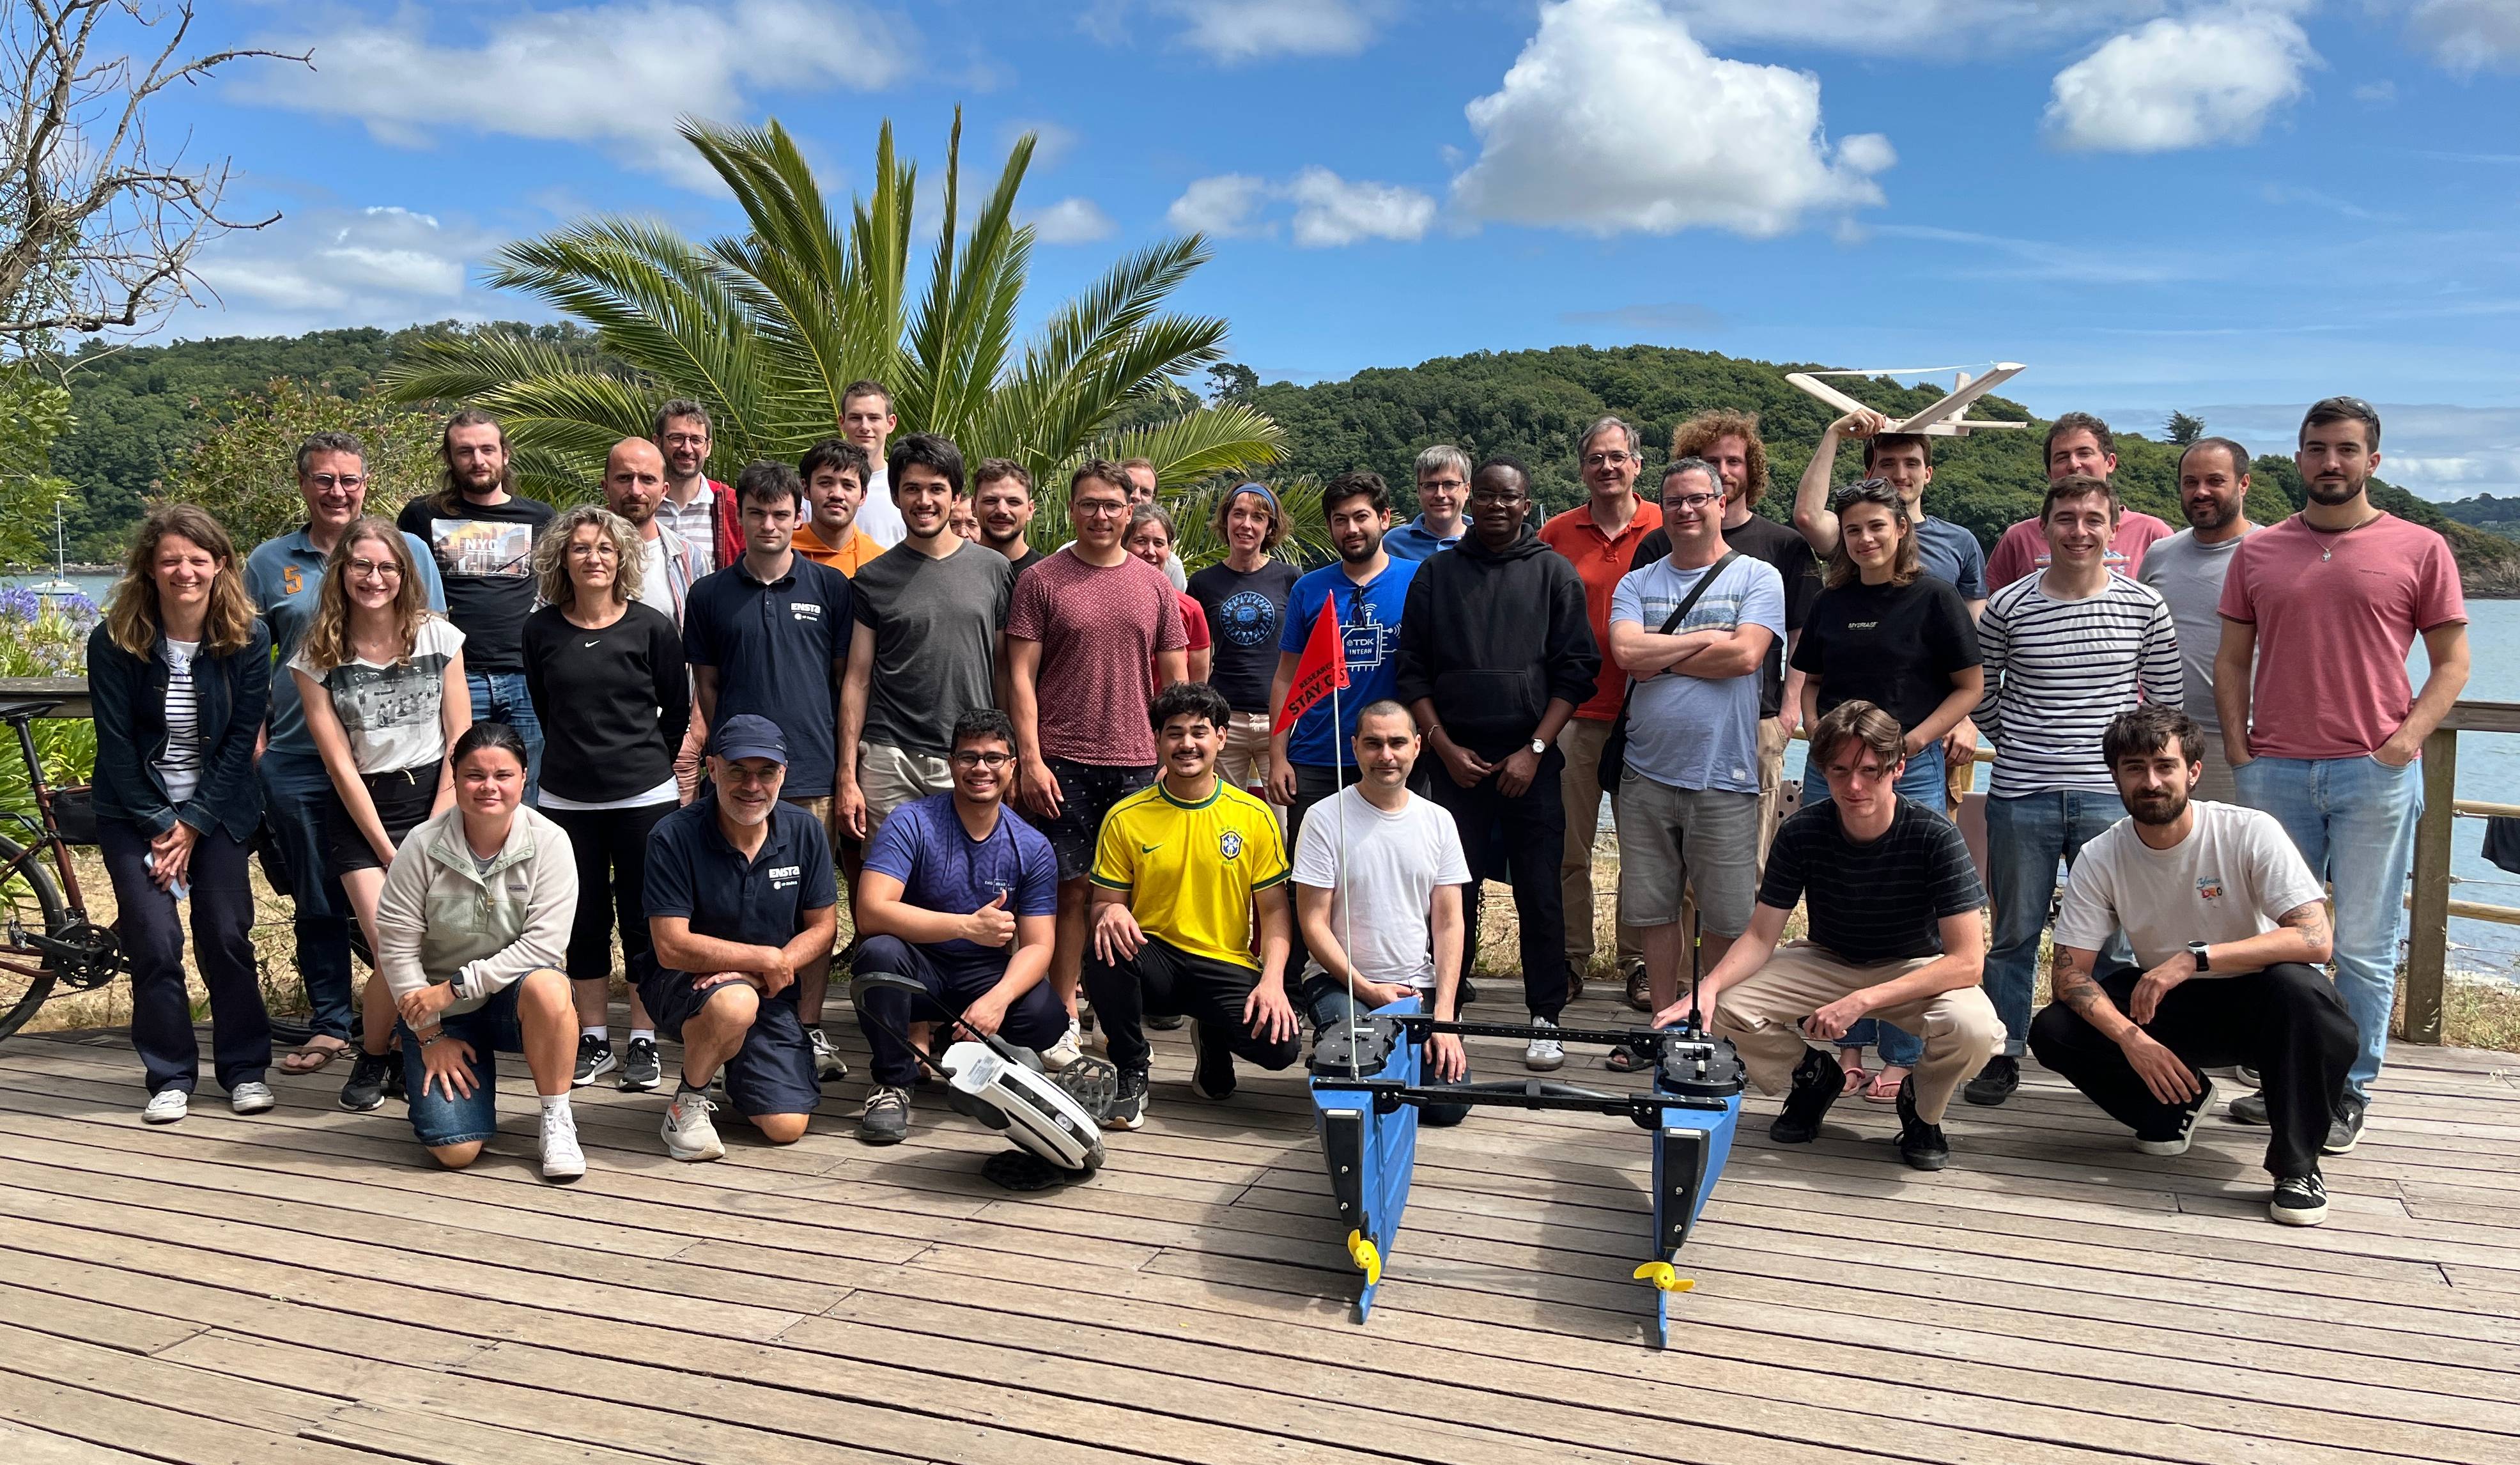
Photo de groupe


